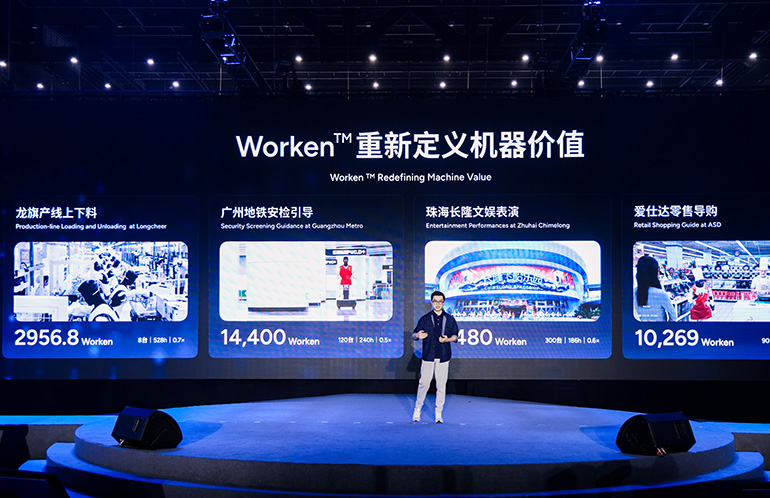
Peng Zhihui, president, CTO, and director of AGIBOT, introduces Worken at AGIBOT Innovation Day 2026. Source: AGIBOT
AGIBOT today introduced Worken, a proposed framework for measuring the productivity of robots in real-world environments, at AGIBOT Innovation Day 2026 in Shanghai. Combining the words “Work” and “Token,” the concept seeks to shift attention beyond the number of robots manufactured or deployed toward how much useful work they can perform autonomously and consistently.
The company also unveiled AHA3, its integrated “three intelligences in one” hardware platform, and highlighted advances in its AGILE motion intelligence framework, including a new self-evolving agent capability. AGIBOT debuted GO-3 Preview, its next-generation embodied AI foundation model, showcased its WITA-Omni 1.0 omni-modal interaction model, and launched the G2 Max industrial robot and Link-U OS 1.0.
The event also featured actual applications across manufacturing and commercial services, demonstrating AGIBOT’s focus on translating robotics innovation into productive work. The company said they reflect its deployment-first focus, with practical innovation spanning robot hardware, locomotion, task and interaction intelligence, operations, and an ecosystem intended to support real-world deployment at scale.
Founded in 2023 as Zhiyuan Xinchuang Technology Co., AGIBOT is focused on embodied AI. The Shanghai-based company‘s portfolio spans humanoid robots, quadrupeds, dexterous systems, and commercial cleaning systems. Last month, AGIBOT said its 20,000th robot had rolled off the production line, and IDC reported that the company led global humanoid robot shipments in the first half of 2026.
 Submit your innovation now!
Worken is a proposed measure of robot productivity
As robots move from large-scale production into increasingly diverse applications, AGIBOT said there is another dimension of progress: the productive work robots can deliver once deployed. In addition to manufacturing scale, technological capabilities, and deployment milestones, the company said sustained autonomous operation and measurable task output are increasingly important indicators of robotic value.
“Over the past few years, the robotics industry has made remarkable progress in hardware, AI models, and large-scale manufacturing,” stated Peng Zhihui, co-founder, president, and chief technology officer of AGIBOT. “But as robots begin working in factories, warehouses, and service environments, we need to answer a more practical question: How much productive work are they actually delivering?”
“Worken is our attempt to develop a new way of answering that question,” he added. “We want to move beyond measuring how many robots are built or delivered and begin measuring how effectively they can perform useful work, autonomously and consistently, in the real world.”
Even deployments involving similar numbers of robots can deliver different levels of productivity, depending on how independently the machines operate, how frequently human intervention is required and how much acceptable work they complete.
AGIBOT described Worken as “effective intelligent work hours,” bringing three factors into a proposed measurement framework:
Worken = Number of Active Robots × Autonomous Working Hours × Output Efficiency Ratio
The first factor counts robots actively performing tasks in real-world environments, rather than units simply manufactured or held in inventory. The second measures time spent working autonomously, rather than total powered-on time.
The third factor assesses productive output against a reference benchmark for a defined task, such as the amount of acceptable work completed by a human worker under established operating standards.
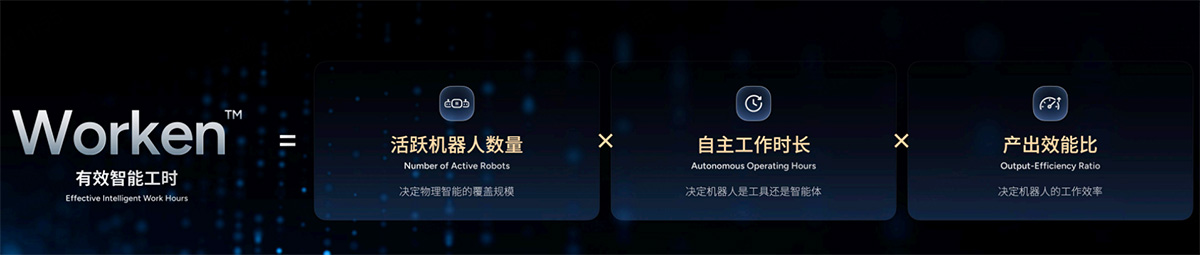
The Worken framework combines the number of active robots, autonomous working hours, and an output efficiency ratio to measure robot productivity in real-world deployments. Source: AGIBOT
By connecting deployment scale, autonomy, and task output in Worken, AGIBOT said it wants to provide a more comprehensive way to describe robotic productivity across applications such as industrial handling, logistics, inspection, and commercial services.
“The concept also opens up a broader discussion about the economics of robotics,” said the company. “While hardware depreciates over time, improvements in software and AI models may enable the same machine to perform more useful work during its operating life. Measuring that output alongside total lifecycle costs could help businesses evaluate the longer-term value of robotic deployments.”
AGIBOT said Worken is an evolving framework that will be further refined through deployments and operational data. By developing task-specific benchmarks and accumulating practical experience across different applications, the company said it hopes that Worken can serve as a widely applicable reference for measuring the productive value of physical AI.
The event also featured the release of the “2026 Embodied Intelligence Industry Innovation Report,” which discussed the industry’s progress toward real-world deployment. Jointly compiled by China Economic Information Service and the Shanghai Industrial Innovation Center of the China Academy of Information and Communications Technology (CAICT), the report included Worken and AGIBOT’s deployment examples as part of its industry analysis.
AGIBOT unveils AHA3 platform and new physical AI models
The AGIBOT Humanoid Architecture, or AHA3, which unifies “three intelligences in one” — locomotion, interaction, and manipulation Intelligence — in an embodied AI system. The company said it designed the third-generation hardware architecture to improve efficiency.
Built on advances in motor-drive technology, integrated computing, and high-speed connectivity including Wi-Fi 6 and 5G, the AHA3 is designed to reduce integration complexity, improve system responsiveness, and support more capable robots in industrial applications.
To support sustained industrial deployment, AGIBOT also introduced a joint liquid-cooling system intended to improve thermal performance during continuous operation, alongside specialized joints with IP67-rated protection for more demanding environments.
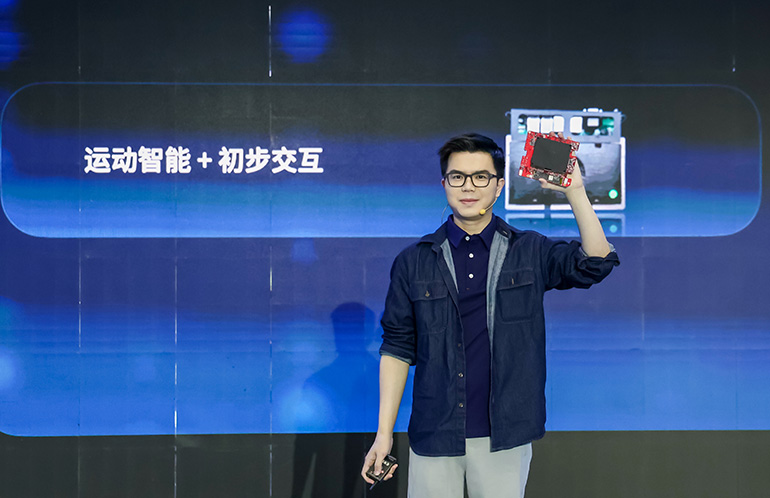
Zhihui shows a hardware component of the AHA3 platform at AGIBOT Innovation Day 2026.
AGILE advances locomotion
AGIBOT showed advances in its AGILE “multimodal, end-to-end locomotion intelligence” framework. The architecture spans general-purpose motion foundation models, generative motion control, integrated whole-body perception and control, and a newly introduced self-evolving agent capability.
AGILE is designed to enable robots to explore the boundaries of their physical capabilities and progressively improve their performance through experience, extending motion intelligence beyond predefined behaviors toward greater autonomy and adaptability.
AGIBOT described the framework as “a shift from motion control toward spatial mobility intelligence, with the goal of helping robots adapt to the layouts and changing conditions of real deployment sites.”
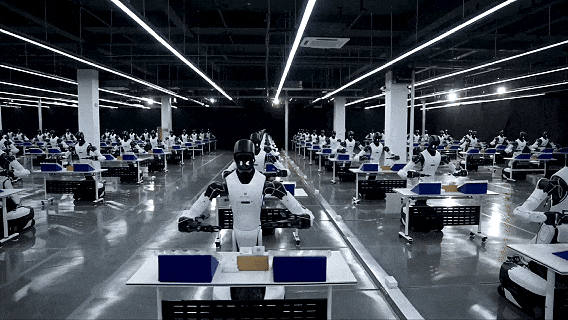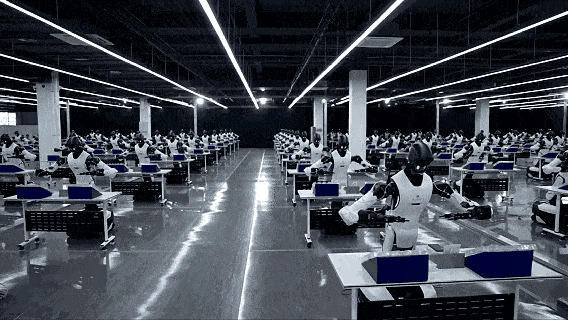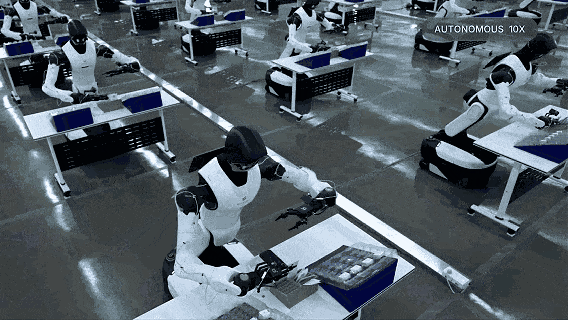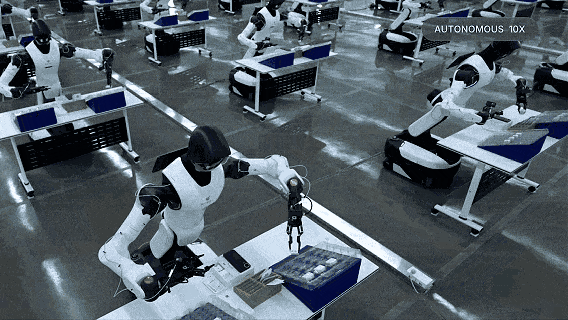
A demonstration of task execution with GO-3 Preview, an embodied AI foundation model integrating reasoning, prediction, and action. Source: AGIBOT
MEgo Glove and OmniHand get hands-on experience
On the data side, AGIBOT introduced MEgo Glove, a wearable tactile data-collection device designed to capture human hand movements and contact information for training embodied AI models.
Offered in Air and Ultra versions, the glove supports finger-pose capture, while the Ultra version adds three-dimensional fingertip and palm force data and torque information. The system is intended to help turn hands-on work experience into training data that can support robots after deployment.
In addition, AGIBOT’s new dexterous hand family includes OmniHand 3 Lite, OmniHand 3 and OmniHand 3 Ultra, as well as the OmniPicker 3 tactile gripper, expanding the options for fine manipulation and task-specific deployment.
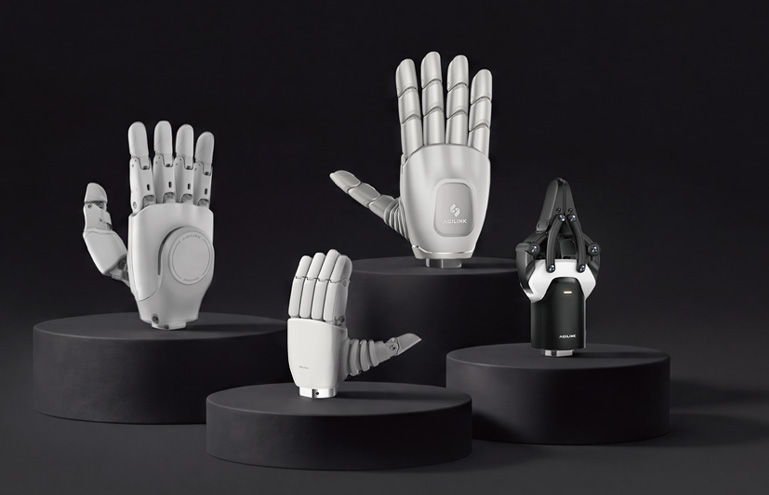
The OmniHand robotic end effectors are designed for dexterous manipulation. Source: AGIBOT
GO-3 Preview is built around WRAM
AGIBOT also debuted GO-3 Preview, a next-generation embodied foundation model built around a World Reasoning Action Model (WRAM). The framework is designed to help robots anticipate the consequences of their actions, adapt to changing environments, and generalize beyond previously learned task sequences.
The company also demonstrated zero-shot and few-shot capabilities and presented its approach to “physical intelligence scaling,” which combines pre-training and post-training with continuous improvement after deployment. This approach aims to enable robots to expand their capabilities through both structured training and experience gained from real-world operations.
AGIBOT also highlighted GO-3 Preview’s benchmark performance. According to evaluation results presented at the event, the model ranked first in both task success rate and process score on RoboDojo, achieved the highest overall score on RoboTwin, and ranked first in overall score on RoboColiseum.
These results demonstrate the model’s performance across multiple evaluation frameworks covering robotic manipulation and task execution. Across task and interaction intelligence, AGIBOT is seeking to connect data, models, robot hardware, and operating scenarios across pre-training, post-training, deployment and day-to-day operations. Feedback from real tasks can then inform subsequent improvements to models and workflows, creating a deployment-driven data flywheel.
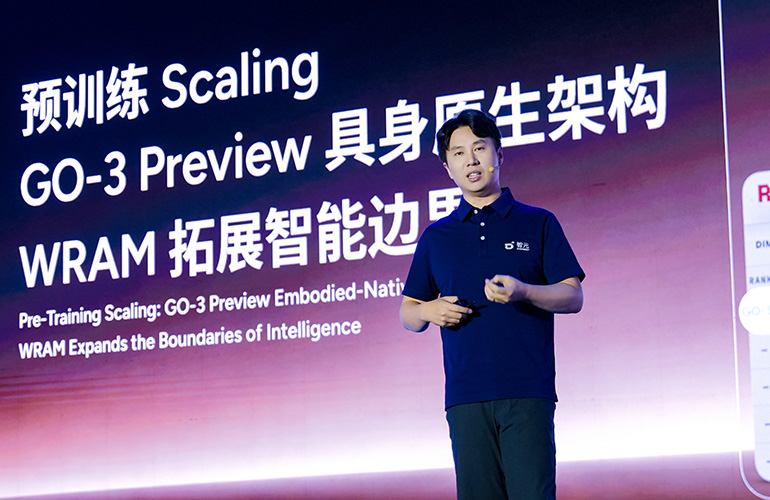
Dr. Yao Maoqing, co-founder, executive director, co-president, and president of the embodied AI business at AGIBOT, explains how GO-3 Preview and feedback from real-world deployments support the company’s data–model–robot–scenario learning loop. Source: AGIBOT
WITA-Omni 1.0 integrates features for human-robot interaction
For human-robot interaction, AGIBOT showcased WITA-Omni 1.0, an omni-modal foundation model that integrates visual perception, speech, real-time dialogue, facial expressions, and physical actions into a continuous interaction system.
The model supports full-duplex conversation, coordinated speech and movement, and on-device deployment, enabling more natural and responsive communication in complex environments. WITA-Omni 1.0 currently ranks first on multiple benchmarks related to embodied interaction, including Daily-Omni.
AGIBOT said AHA3, AGILE, GO-3 Preview and WITA-Omni 1.0 reflect its progress across integrated hardware architecture, locomotion intelligence, task execution and human-robot interaction. The company is also expanding its data collection, simulation and training capabilities through initiatives including AGIBOT WORLD 2026, the MEgo product family and Genie Sim 3.0, supporting the continued development of its physical AI models. This week, it also launched Genie Studio 2.0.
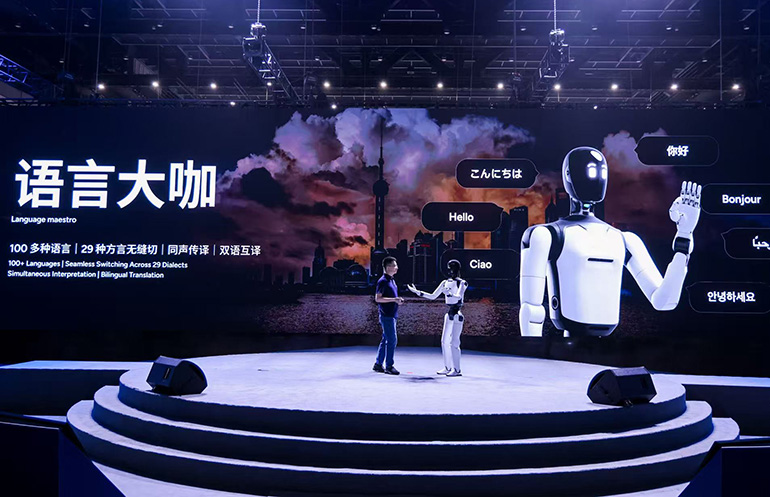
Xiong Yan, partner, executive director, co-president, president of central R&D, and president of the interaction business at AGIBOT, presents WITA-Omni 1.0 and its planned deployment roadmap for more natural, multimodal human–robot interaction. Source: AGIBOT
AGIBOT Launches G2 Max
AGIBOT launched G2 Max, a heavy-duty industrial robot designed for manufacturing and logistics applications. Featuring 21 degrees of freedom, a dual-arm handling capacity of up to 40 kg (88 lb.) and an adjustable working height ranging from 0.1 to 2.5 m (0.3 to 8.2 ft.), the robot is built for demanding material-handling tasks.
G2 Max’s force-controlled manipulation, omnidirectional mobility, and multiple safety features are intended to support efficient operations alongside existing industrial equipment and workflows.
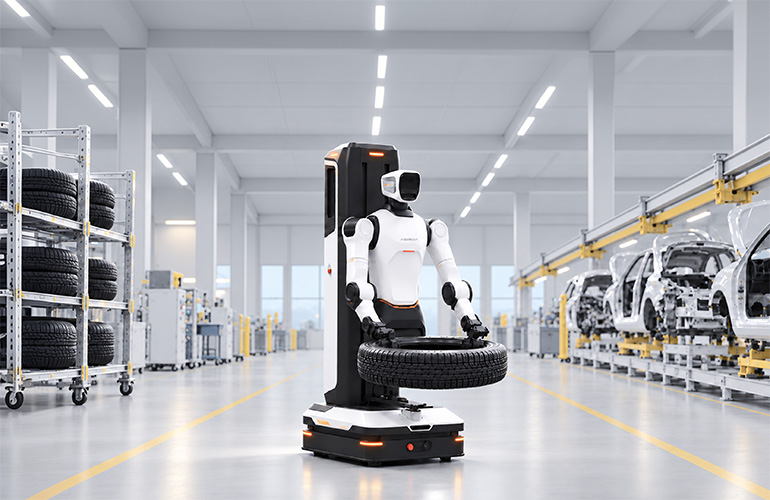
The G2 Max industrial robot features dual-arm handling, force-controlled manipulation, and omnidirectional mobility for manufacturing and logistics applications. Source: AGIBOT
AGIBOT touts real-world deployments
To demonstrate how its G2 family performs in real operating environments, AGIBOT discussed deployments including tablet production, semiconductor packaging and testing, CNC machine tending, and logistics operations.
At computer maker Longcheer, robots are used in production-line material handling, where operating performance is assessed against cycle time, sustained operation and successful task completion. These are key performance indicators for manufacturing teams, said AGIBOT.
AGIBOT also presented G2 Max applications covering industrial material transport, warehouse handling, and pallet-related operations. These applications require more than a robot completing an isolated task: machines must operate safely around people and equipment, handle changes in the environment, and deliver consistent results over extended periods.
Beyond manufacturing, AGIBOT highlighted deployments in transportation and visitor-service environments, including Guangzhou Metro and the Chimelong tourism and entertainment complex. Robots perform tasks ranging from guiding visitors and answering questions to providing interactive services.
Unlike industrial handling, these applications place particular demands on speech comprehension, responsiveness, and sustained human-robot interaction. In this approach, AGIBOT asserted that deployment is not a one-off delivery milestone but an ongoing cycle of site integration, stable operation, and continuous improvement.
The company said the differences between factory and service work helps explain why Worken uses task-specific output benchmarks for different value. AGIBOT is using real deployment data and operating experience to explore how measures of autonomous working time and task output can be applied meaningfully in each setting.
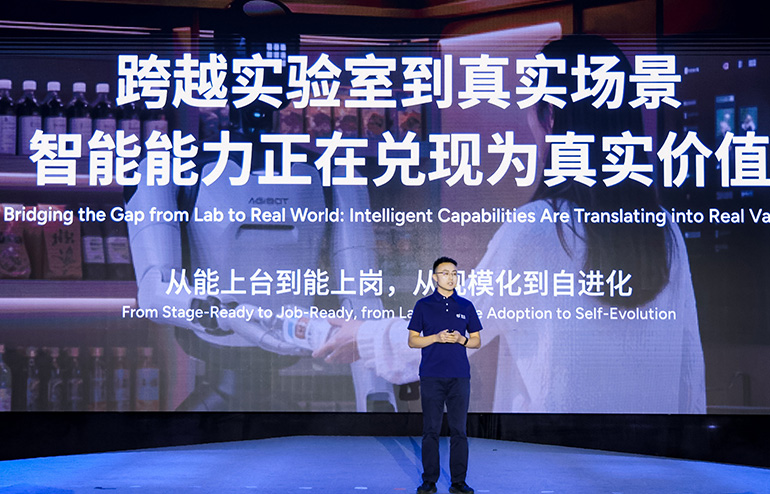
Chuang Wang, partner, executive director, senior vice president, and president of the general-purpose humanoid business at AGIBOT, outlines the four capabilities behind scalable robot deployment: product readiness, manufacturing, on-site deployment, and ongoing operations. Source: AGIBOT
Link-U OS 1.0 part of wider AGIBOT open-source plans
AGIBOT officially released Link-U OS 1.0, which it claimed is “the industry’s first operating system purpose-built for embodied intelligence.” Built on a unified hardware abstraction layer, an embodied intelligence-native kernel, and a service framework, Link-U OS connects robot hardware with upper-layer applications.
The company is offering Link-U OS 1.0 as “a full-stack technology foundation spanning the entire process from development to deployment, and from underlying hardware enablement to upper-layer application support.”
The operating system has already been validated on mass-produced robots. Link-U OS 1.0 is currently being trialled by selected ecosystem partners, with plans for it to become fully open-source by the end of 2026.
AGIBOT also announced its OpenAtom Foundation Platinum Level Sponsorship and the donation of the Link-U OS project to the foundation. Through the OpenAtom Humanoid Community Joint Building Initiative, the two parties will jointly develop an open-source community for humanoid robots; promote unified technical interfaces and standards; and advance joint development, testing and validation, and talent training.
AGIBOT’s ecosystem now spans 255 universities, 511 enterprises, and more than 80,000 developers, supported by ongoing collaboration and research initiatives. The company said its partner and research ecosystem will extend deployment capabilities into additional scenarios and support repeatable implementation beyond individual pilots.
Tell Us What You Think!